Dr. Hamidreza Kasaei
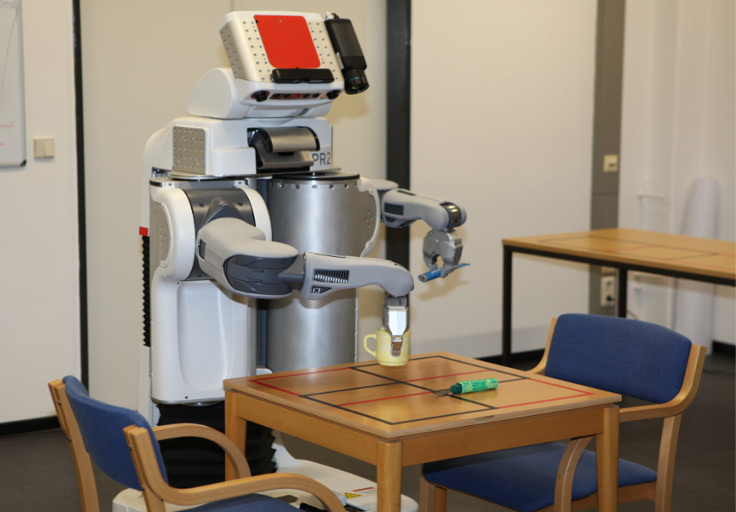
My research interest lies at the intersection of machine learning, robotics, and machine vision, particularly in the area of open-ended learning, 3D object perception, grasp affordance detection, and object manipulation. My goal is to achieve a breakthrough in robotics by enabling robots to learn from past experiences incrementally and safely interact with human users. I have been investigating on active perception, where robots use their mobility and manipulation capabilities not only to gain useful perceptual information but also to predict the next-best-view for improving the performance of object detection and manipulation. I have evaluated my works on different robotic platforms, including PR2, robotic arms (UR5e, Franka, Kinova), and humanoid robots. I am leading the Interactive Robot Learning Laboratory (IRL-Lab) focusing on Lifelong Interactive Robot Learning in the areas of 3D Object Perception, Grasp Affordance, and Object Manipulation. Navigate my webpage and IRL-Lab page if you want to know more about my research.
I developed the "Cognitive Robotics" course from scratch in 2019 and improving its content constantly. This course covers a diverse set of topics that focus on addressing the most critical aspects of building a cognitive robotic system. We recently wrote a survey paper about the state of lifelong learning in service robots that has been published in Journal of Intelligent & Robotic Systems (available online here). This survey paper covers all the topics of the cognitive robotics course in a concise and brief manner to help students in easy remembrance and quick revision. I will try to share my knowledge with you throughout the course!